047 - Towards Autonomous Fish Processing Through Vision-Language-Action Models
Project Overview
One Liner: Vision-Guided Robotics for Automated Fish Processing
Company: Department of Agriculture
Subject to change:
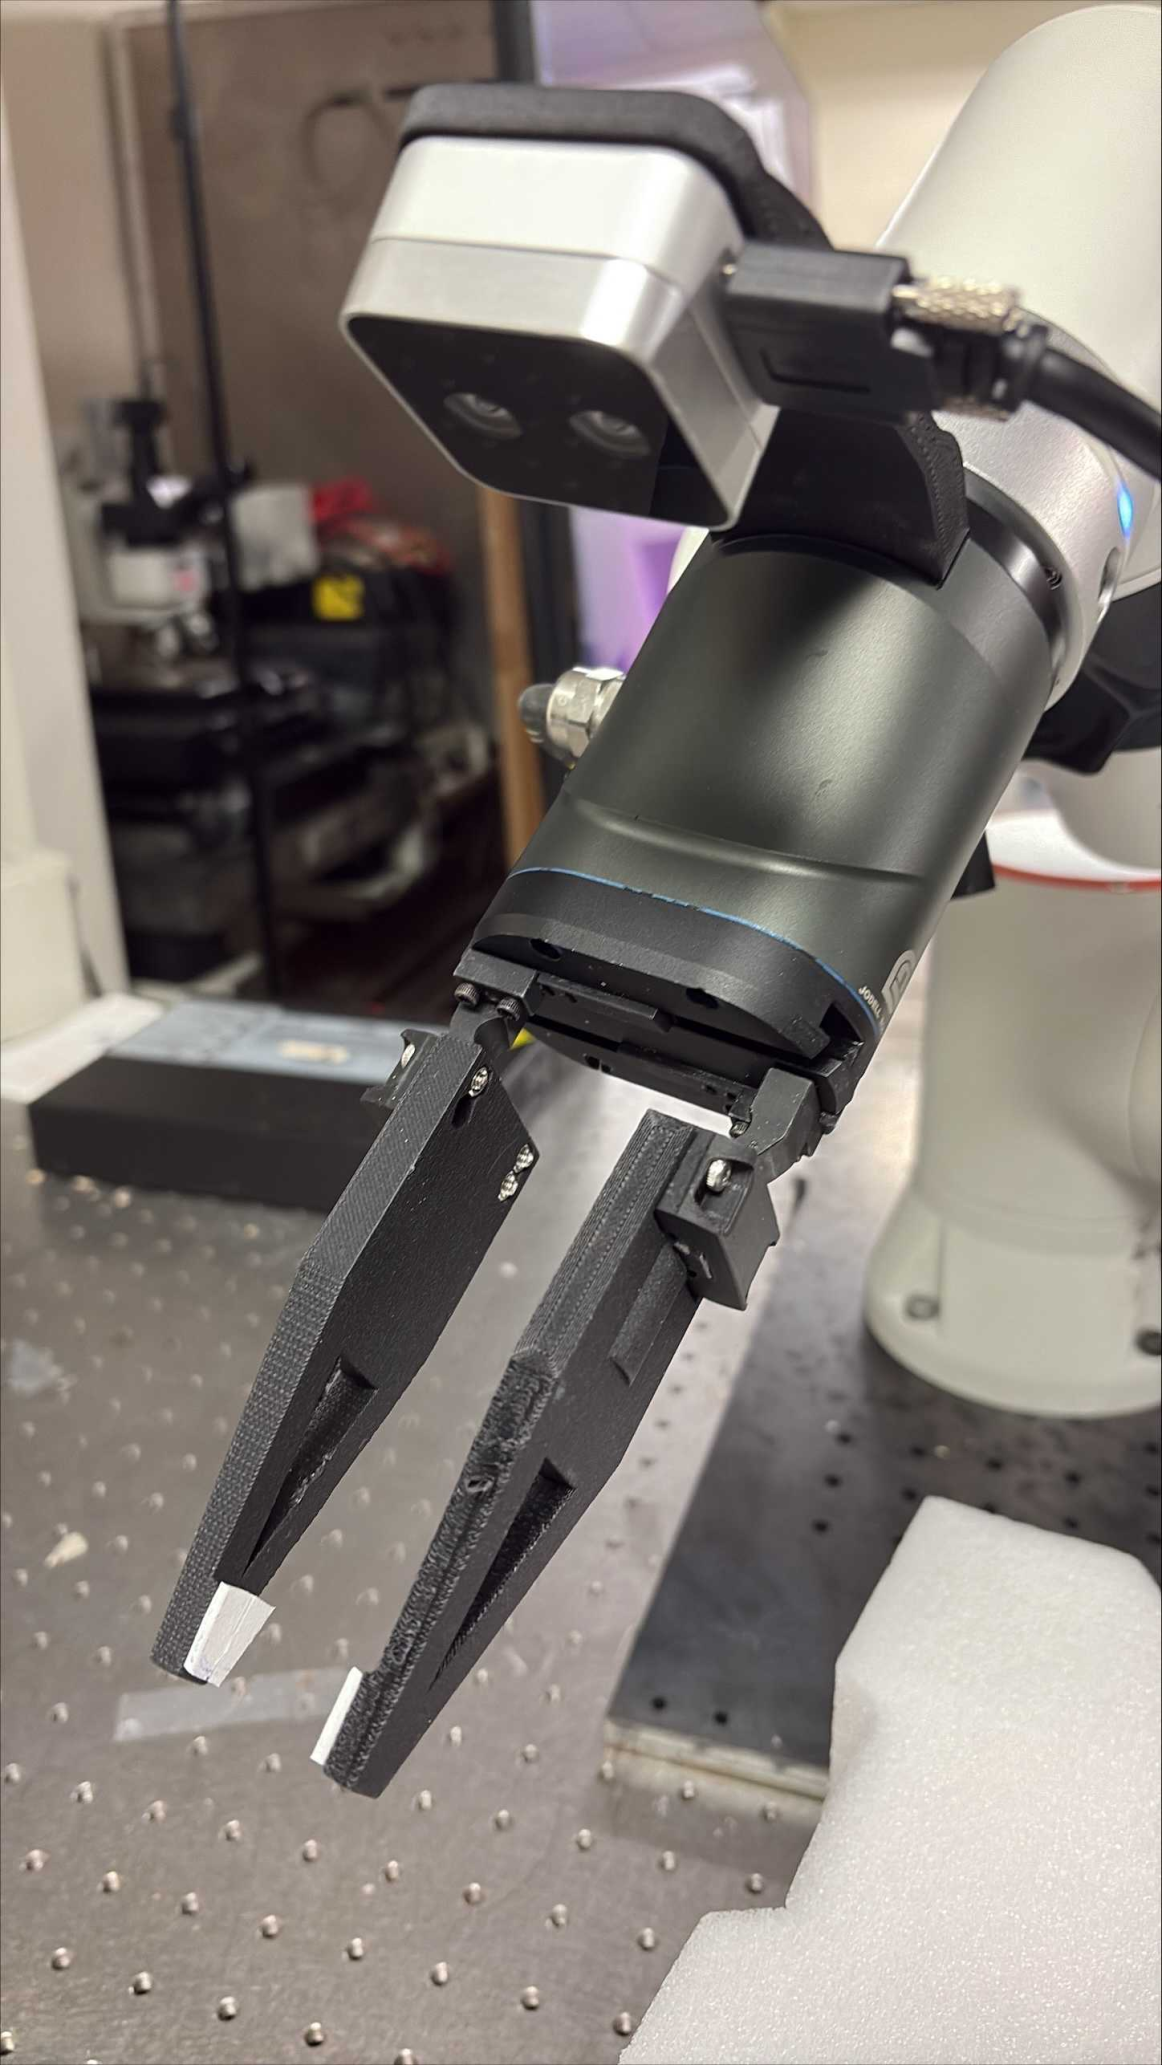
Rising demand for efficient, resilient domestic food production has increased interest in robotic handling of natural products, and fish are a particularly difficult case: their bodies are slippery, deformable, and highly variable in size and shape. Skilled human workers handle fish with ease, an ability that appears to rest on quickly judging each specimen's position, orientation, and form, then adjusting grip and motion to match. In this work, we draw on that principle by estimating the pose and shape of individual fish from visual input, and using that estimate to select a suitable grasp and plan the arm motion needed to acquire and manipulate the fish, without per-specimen or per-species reprogramming. We develop the vision guidance pipeline and the arm and gripper control system as a unified methodology, and evaluate it on physical hardware using fish spanning a range of sizes, shapes, and surface conditions. We measure grasp reliability, handling consistency, and generalization to specimens not seen during development. [Insert results here once available.] This work contributes a reproducible methodology and an empirical characterization of vision-guided grasping for fish processing, supporting safer, more efficient, and more resilient food production in service of U.S. agricultural and food-system needs.
No video available.
Screenshots
1 image(s)